대표어
권호기사보기
| 기사명 | 저자명 | 페이지 | 원문 | 기사목차 |
|---|
결과 내 검색
동의어 포함
목차
표제지=0,1,1
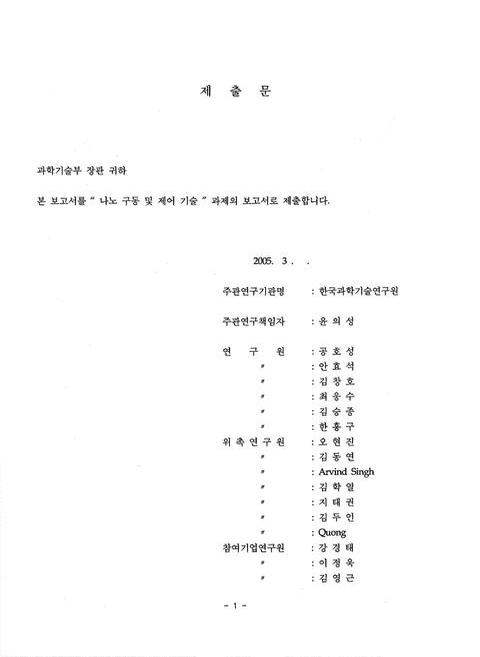
제출문=1,2,2
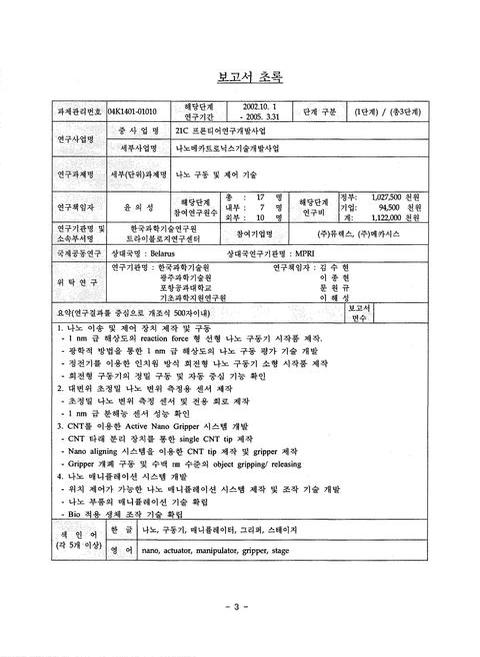
보고서 초록/윤의성=3,4,2
요약문=5,6,4
SUMMARY=9,10,4
CONTENTS=13,14,2
목차=15,16,2
제1장 연구개발과제의 개요=17,18,1
제1절 연구 목적=17,18,1
제2절 연구 필요성=17,18,2
제3절 연구 내용 및 범위=18,19,3
제2장 국내외 기술개발 현황=21,22,6
제3장 연구개발수행 내용 및 결과=27,28,1
제1절 선형 나노 구동기=27,28,30
제2절 회전형 나노 구동기=57,58,26
제3절 대변위 나노 변위 측정 센서=83,84,32
제4절 CNT를 이용한 액티브 나노 그립퍼 시스템=115,116,71
제5절 나노 매니퓰레이션 시스템=186,187,29
제6절 나노 이송 시스템=215,216,32
제4장 목표달성도 및 관련분야에의 기여도=247,248,1
제1절 연도별 연구목표 및 평가 착안점=247,248,1
제2절 연구 개발 목표의 달성도=248,249,3
제3절 기술 수준 성취도=251,252,1
제4절 기술 발전에의 기여도=251,252,2
제5장 연구개발결과의 활용계획=253,254,2
제6장 연구개발과정에서 수집한 해외과학기술정보=255,256,14
제7장 참고문헌=269,270,6
특정연구개발사업 연구결과 활용계획서=275,276,19
영문목차
[title page etc.]=0,1,9
SUMMARY=9,10,4
CONTENTS=13,14,4
Chapter 1. Introduction=17,18,1
Section 1. Objectives=17,18,1
Section 2. Necessities=17,18,2
Section 3. Contents and scope=18,19,3
Chapter 2. State of the art=21,22,6
Chapter 3. Research details and results=27,28,1
Section 1. Linear nanoactuator=27,28,30
Section 2. Rotational nanoactuator=57,58,26
Section 3. Nano displacement sensor for a long range measurement=83,84,32
Section 4. Active nano gripper system using CNT=115,116,71
Section 5. Nanomanipulation system=186,187,29
Section 6. Nanodrive system=215,216,32
Chapter 4. Achievement of objectives and contribution to the related research field=247,248,1
Section 1. Annual objectives and evaluation standard=247,248,1
Section 2. Achievement of objectives=248,249,3
Section 3. Accomplishment of technology=251,252,1
Section 4. Contribution of technology development=251,252,2
Chapter 5. Application plans of developed results=253,254,2
Chapter 6. Information of overseas science and technology=255,256,14
Chapter 7. References=269,270,25
*표시는 필수 입력사항입니다.
| 전화번호 |
|---|
| 기사명 | 저자명 | 페이지 | 원문 | 기사목차 |
|---|
| 번호 | 발행일자 | 권호명 | 제본정보 | 자료실 | 원문 | 신청 페이지 |
|---|
도서위치안내: / 서가번호:
우편복사 목록담기를 완료하였습니다.
*표시는 필수 입력사항입니다.
저장 되었습니다.