대표어
 https://www.census.gov/library/working-papers/2026/adrm/RRS2026-01.html
권호기사보기
| 기사명 | 저자명 | 페이지 | 원문 | 기사목차 |
|---|
결과 내 검색
동의어 포함
Title page 1
Contents 1
Abstract 2
1. Introduction 3
2. Description of the research problem 4
3. Inference under noise addition 5
3.1. Truncated modification 7
3.2. Discrete Noise Addition 10
3.3. Likelihood approach based on Z = X + ϵ 13
3.4. Predicting X from a Released Z 15
3.5. Simulation Results 15
3.5.1. MLE: Gaussian Noise 15
3.5.2. MLE: Laplace Noise 18
3.5.3. Bayes: Gaussian Noise 21
3.5.4. Bayes: Laplace Noise 23
3.5.5. Conditional Inference on X 25
4. Synthetic Data 37
4.1. Plug-In Sampling (PLS) 38
4.2. Posterior Predictive Sampling (PPS) 43
5. Multiple imputations 52
5.1. Noise Addition 52
5.2. Plug-In Sampling (PLS) 52
5.3. Posterior Predictive Sampling (PPS) 52
6. Comparison of three methods and concluding remarks 55
References 56
Tables 9
Table 3.1. Monte Carlo estimates of mean(U/n), variance, and MSE of θ = U/n under Gaussian noise for θtrue ∈ {0.1, 0.3, 0.5, 0.8} and... 9
Table 3.2. Monte Carlo estimates of mean(U/n), variance, and MSE of θ = U/n under Laplace noise with standard deviation σ (scale b = σ/√2)... 10
Table 3.3. Simulated mean and variance of the maximum-likelihood estimator θ under Gaussian noise with standard deviations σ = 0.5, 1.0,... 17
Table 3.4. Simulated mean and variance of the maximum-likelihood estimator θ under Laplace noise with standard deviations σ = 0.5, 1.0,... 20
Table 3.5. Simulated mean and variance of the Bayes estimate θBayes under Gaussian noise with standard deviations σ = 0.5, 1.0, 2.0,... 23
Table 3.6. Simulated mean and variance of the Bayes estimate θBayes under Laplace noise for each true value θtrue ∈ {0.1, 0.3, 0.5, 0.8},... 25
Table 3.7. Simulated posterior probabilities P(true_x / Z) under Gaussian noise for standard deviations σ = 0.5, 1.0, 2.0, 5.0 and sample sizes... 27
Table 3.8. Posterior probabilities P(X = x / Z) for n = 20 under Gaussian noise with σ = 5 28
Table 3.9. Simulated posterior probabilities P(true_x / Z) under Laplace noise for standard deviations σ = 0.5, 1.0, 2.0, 5.0 and sample sizes... 30
Table 3.10. Posterior probabilities P(X = x / Z) for n = 20 under Laplace noise with σ = 5 for various true parameter values θ 31
Table 3.11. Bayesian posterior predictive performance under Gaussian noise: for each true value θtrue ∈ {0.1, 0.3, 0.5, 0.8}, sample size... 33
Table 3.12. Bayesian posterior predictive probabilities under Gaussian noise (σ = 5, n = 20): we report the probability of the MAP estimate,... 34
Table 3.13. Bayesian posterior predictive performance under Laplace noise: for each true parameter θtrue ∈ {0.1, 0.3, 0.5, 0.8}, sample size... 36
Table 3.14. Bayesian posterior predictive probabilities under Laplace noise (σ = 5, n = 20): for each true parameter θ ∈ {0.1, 0.3, 0.5, 0.8}... 37
Table 4.1. 100 × True Probability P(ZPLS = x / X = x) by n and X/n 39
Table 4.2. Percentage of PLS Simulations where X is fixed and Z = X by θ and n 40
Table 4.3. Percentage of PLS Simulations where Z = X by θ and n 40
Table 4.4. True Probability P(ZPPS = x / X = x) by n and X/n 49
Table 4.5. Percentage of PPS Simulations where X is fixed and Z = X by n and X/n 49
Table 4.6. Percentage of PPS Simulations where Z = X by θ and n 49
Table 5.1. θ∗ Estimates based on PPS Imputations with Fixed θ∗ 53
Table 5.2. X Estimates based on PPS Imputations with Fixed θ∗ 54
Table 5.3. Percentage of Simulations with X = round(Z) based on m PPS Imputations 54
Figures 18
Figure 1. Empirical distributions of the standardized statistic U for the MLE under Gaussian noise 18
Figure 2. Empirical distribution of the standardized error U for the MLE under Laplace noise 21
Figure 3. UPLS Simulation Histogram by θ and n 41
Figure 4. Variance Stabilized UPLS Simulation Histogram by θ and n 42
Figure 5. UPPS Simulation Histogram by θ and n 50
Figure 6. Variance Stabilized UPPS Simulation Histogram by θ and n 51
In this paper we consider the inferential problem for a Binomial proportion in situations when the exact number of units possessing an attribute under consideration is unavailable due to privacy reasons; however a synthesized version of this number is available.
The inference problem is addressed under three types of available information: noise added version and plug-in sampling based and posterior sampling based data.
A comparison of the three modes of data source is made based on inferential accuracy and a measure of privacy.*표시는 필수 입력사항입니다.
| 전화번호 |
|---|
| 기사명 | 저자명 | 페이지 | 원문 | 기사목차 |
|---|
| 번호 | 발행일자 | 권호명 | 제본정보 | 자료실 | 원문 | 신청 페이지 |
|---|
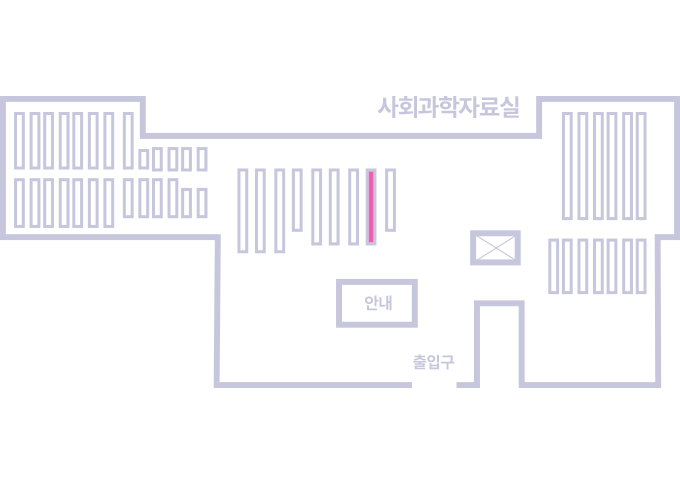
도서위치안내: / 서가번호:
우편복사 목록담기를 완료하였습니다.
*표시는 필수 입력사항입니다.
저장 되었습니다.